Ellis

PORTFOLIO / RESUME

Ellis

Graduate Student in Intelligent Construction & Construction Robotics

Well-versed in construction scenarios, with a focus on construction robotics, visual algorithm development, and AI large models. Experienced in end-to-end product lifecycle management—from 0-to-1 product definition and development to successful project deployment. Passionate about AI product development and proficient in building AI workflows.

Research & Course Projects

Automatic Spraying Robot Based on Construction Suspended PlatformEntrepreneurship

2025.02 - Present

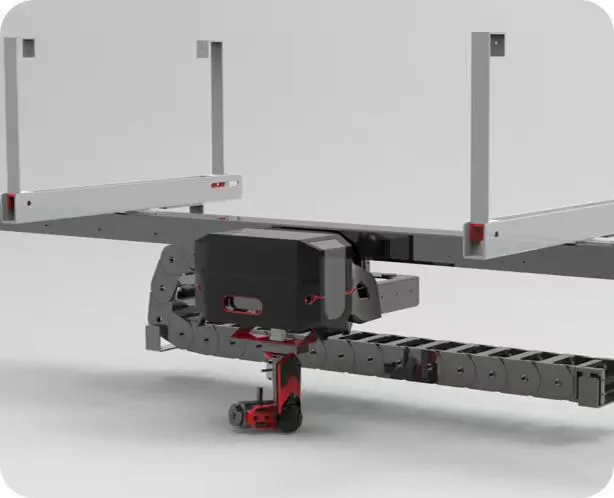
Automatic Spraying Robot Based on Construction Suspended Platform

To address challenges such as an aging workforce and high-altitude construction risks, we developed an unmanned automated exterior wall spraying robot based on a suspended platform. This system efficiently replaces manual high-altitude operations without disrupting existing construction workflows, effectively shortening project timelines and reducing costs.

  • Third Prize, 1st China Graduate Smart Construction Innovation Competition
  • Best Design Award, XbotPart Smart Construction Training Camp
Research on Multi-Target Recognition Algorithms for Exterior Wall Spraying ScenariosResearch

2025.12 - Present

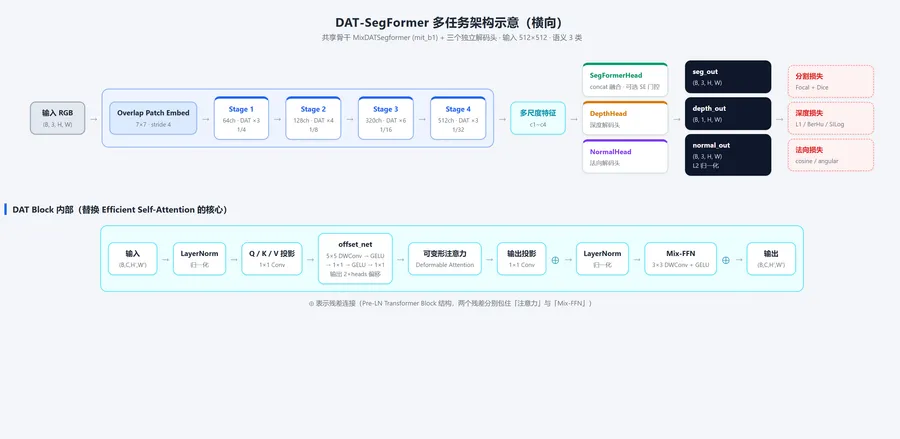
Research on Multi-Target Recognition Algorithms for Exterior Wall Spraying Scenarios

Developed a lightweight semantic segmentation model tailored for exterior wall construction scenarios and deployed it on edge devices, enabling real-time multi-target recognition in outdoor spraying operations.

Design of a Portable Robot Control CabinetEntrepreneurship

2025.07 - 2026.08

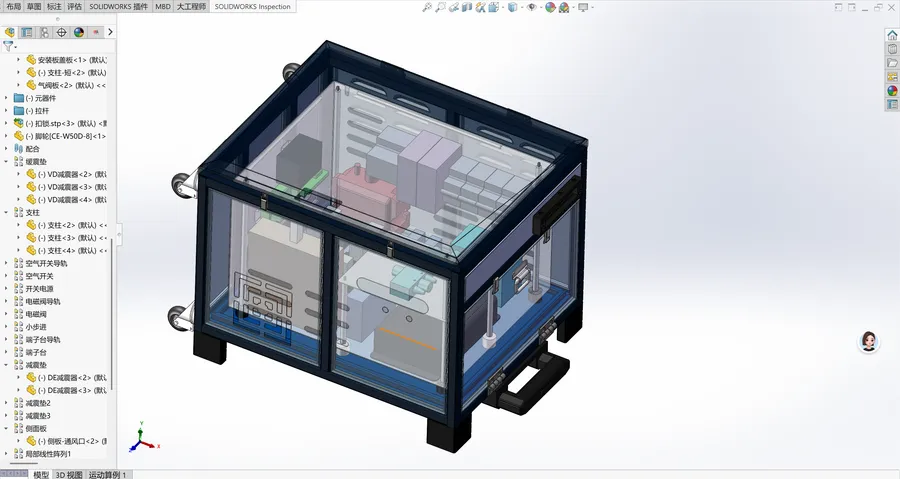
Design of a Portable Robot Control Cabinet

Completed the design, 3D modeling, and assembly of an electrical control cabinet using SolidWorks, and generated detailed engineering drawings for manufacturing.

Personal Exploration

2025

AI Programming Mini-Games

AI programming mini-games built with zero-code tools and deployed to mobile devices.

2024

Machine Vision Coursework

Complete image restoration and 3D reconstruction using OpenCV, and deliver a course report along with a demonstration video.